High Precision Hexapods
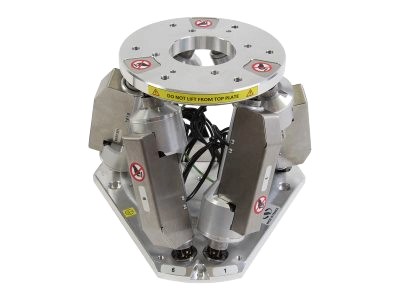
In comparison to stacked stages, Newport's HXP Series Hexapods offer an easy, elegant solution to complex, multi-axis motion in a compact construction.
Manufacturer: Newport — USA
Overview
In comparison to stacked stages, Newport's HXP Series Hexapods offer an easy, elegant solution to complex, multi-axis motion in a compact construction. Their dedicated firmware simplifies the programming of complex motion through the use of two coordinate systems and automatically computes coordinate transformations for straightforward programming. Parallel kinematic motion devices provide six degrees of freedom in a compact solution, with no moving cables and error compensated motion.
Parallel Kinematic Motion
Hexapods are effective solutions to complex motion applications that require high load capacity and accuracy in up to six independent axes. As an alternative to stacking multiple stages, hexapods have no moving cables, are lower in overall cost, and offer error compensated motion.
High Precision Actuators
The top plate of HXP hexapods is driven by six industry-proven, high performance actuators with encoder feedback at the leadscrew nut to provide precise minimum incremental motion, low backlash, and fast speed.
Innovative Actuator Joints
HXP hexapods utilize ceramic spherical joints, rather than ordinary universal joints, to connect the actuators to the base and moving top plate, ensuring constant preload over full travel and enhancing rigidity while avoiding corrosion.
Two Virtual Centers of Rotation
Users can program up to two virtual pivot points, Tool and Work, without calculating coordinate system transformations or powering down the controller, simplifying complex motion for easy user program development.
RightPath Trajectory Control
Newport's RightPath trajectory control minimizes the runout of hexapods during scanning motion along line, arc, or rotation trajectories in either Work or Tool coordinates, while maintaining constant velocity and equal acceleration and deceleration.
Common Specifications
| Specification | High Precision Hexapods |
|---|---|
| Motor | DC Servo |
| Thread Type | M6 |
| Cable Length | 3 m |
| Connectors | DB25 Male ×6 |
Model Comparison
| Specification | HXP50-MECA | HXP100-MECA | HXP100P-MECA |
|---|---|---|---|
| Platform Diameter | 125 mm | 200 mm | 200 mm |
| Travel Range X, Y, Z | ±17, ±15, ±7 mm | ±27.5, ±25, ±14 mm | ±27.5, ±25, ±14 mm |
| Travel Range ΘX, ΘY, ΘZ | ±9, ±8.5, ±18° | ±11.5, ±10.5, ±19° | ±11.5, ±10.5, ±19° |
| Minimum Incremental Motion X, Y, Z | 0.10, 0.10, 0.05 µm | 0.5, 0.5, 0.25 µm | 0.10, 0.10, 0.05 µm |
| Centered Load Capacity | 50 N | 200 N | 60 N |
| Weight | 2.2 kg | 7.2 kg | 7.2 kg |